

Backed by Y Combinator
Robots fail.Ask your agent why.
Give your AI coding agent the run.Then re-run its fix on the same inputs.
Cerulion + Flashback · A dashcam for your robot
Keep the moments around a failure.
Save recent robot history as MCAP—on a runtime fault or on demand.
Capture on demand
cerulion flashbackRead the run.See the evidence.
Hindsight finds the moment.
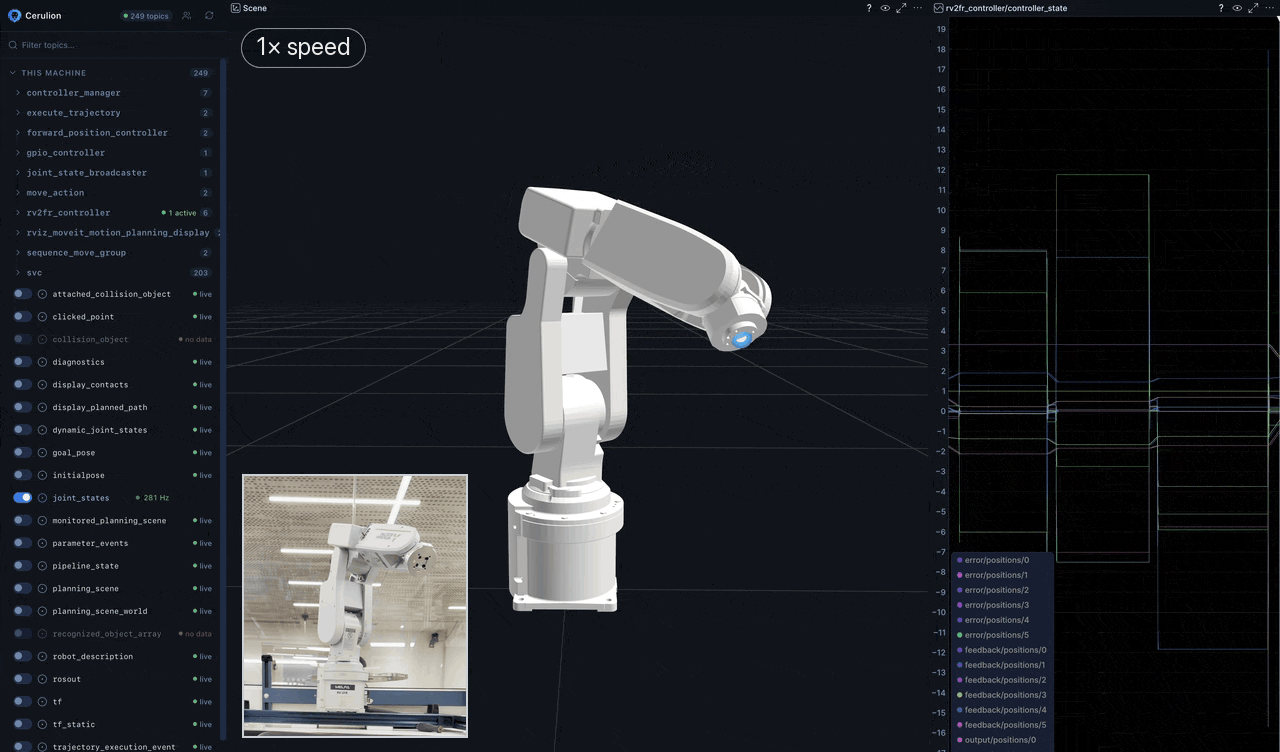
Studio shows the frame.
MCAP
Hindsight + Studio
Example agent exchange
You
What happened here?
New code.Same inputs.
Supported native replay. Compare changed outputs.
Terminal · example
$ cerulion bag play run.mcap \ --resim all --verifyRecorded
Current
Compare native outputs
Turn this runinto a test.
Supported native recordings. Compare outputs in CI.
CI · example
$ cerulion bag play run.mcap \ --resim all --verify \ --tolerance tolerance.yaml
On the robot.At your desk.
Bring live topics into Studio across machines.
Back to the robot.
Keep the run. Test the next change.